Robot tending cell for a welding station
Automotive supplier · client name withheld
The problem. A robot had to load a flat stainless part and three to five small round parts onto a weld fixture, then unload the finished part, in under 20 seconds. Sizes and hole positions changed between jobs, and the 3 × 5 ft cell had to still run by hand.
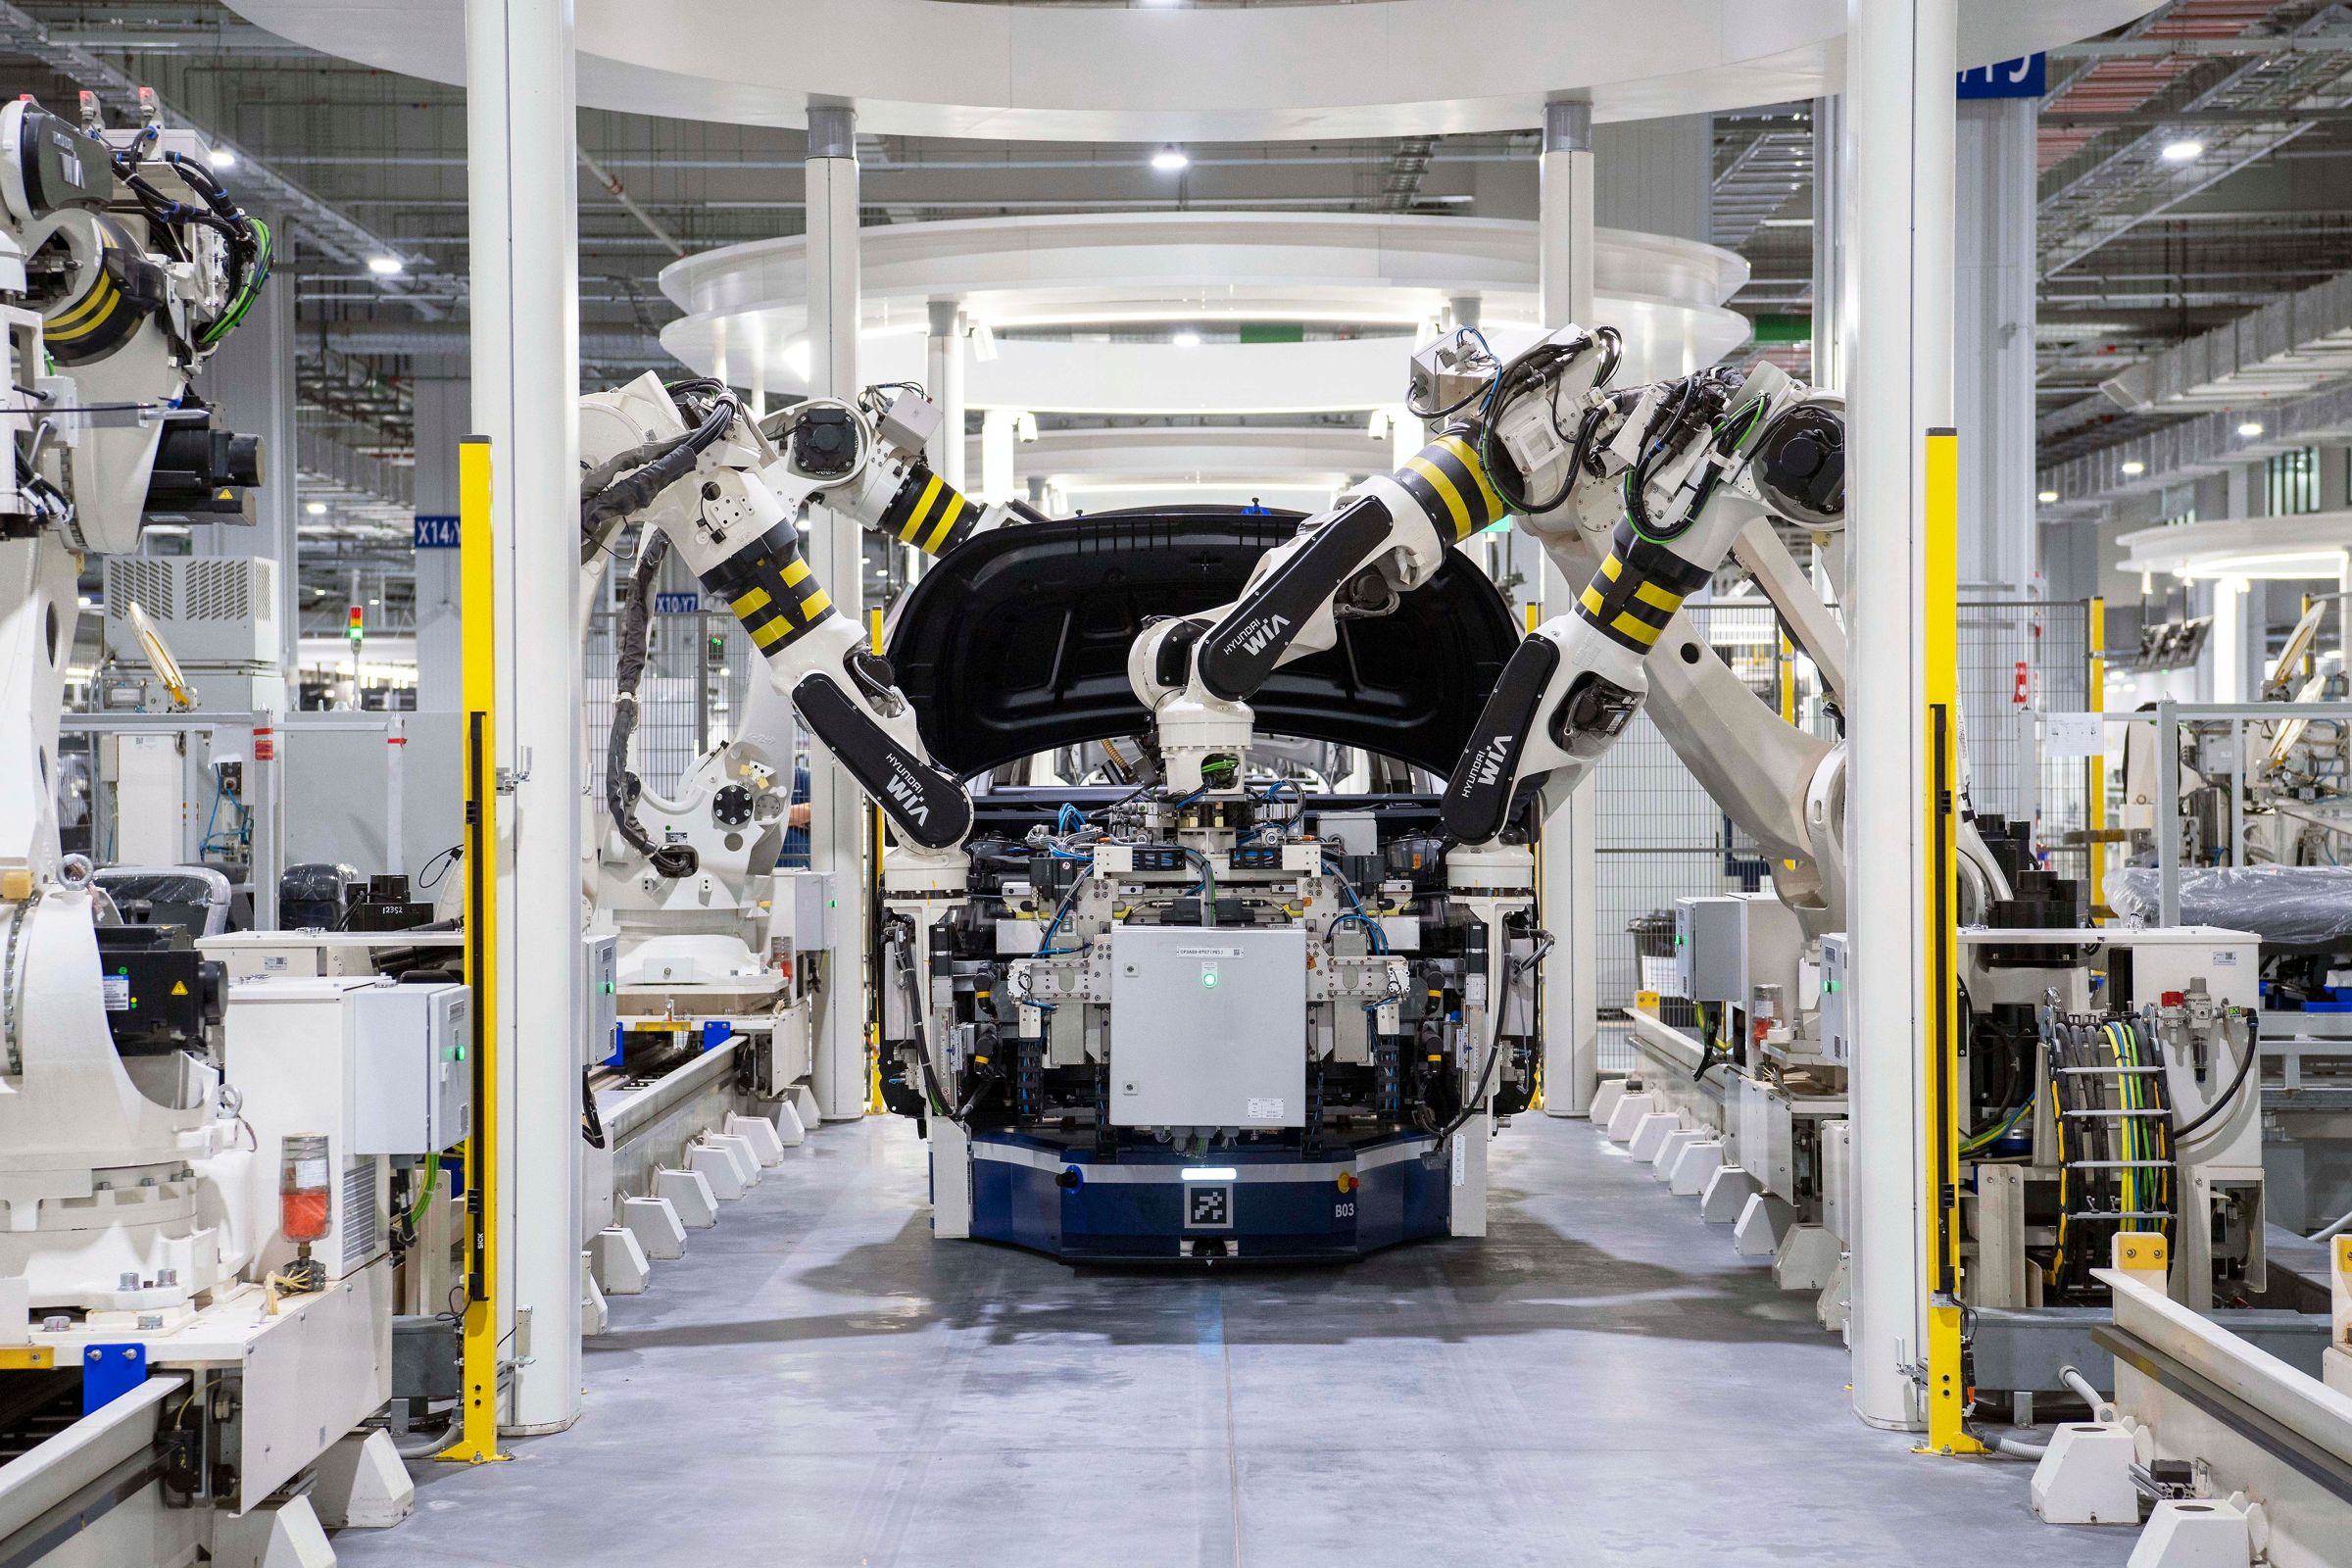
The design. The whole cell: a rolling frame that locks into place; interlocked drawers holding 200+ lb, so an operator reloads one while the robot works from the other; area scanners that stop the robot if anyone reaches in; servo-set locating pins; and the gripper.
The decision that mattered. A cam-driven gripper: one servo moves every suction cup the same distance, with no actuator per cup.
Result. About 10-second cycles against a 20-second target. Designed in six weeks, installed two to three months later, still running today.